

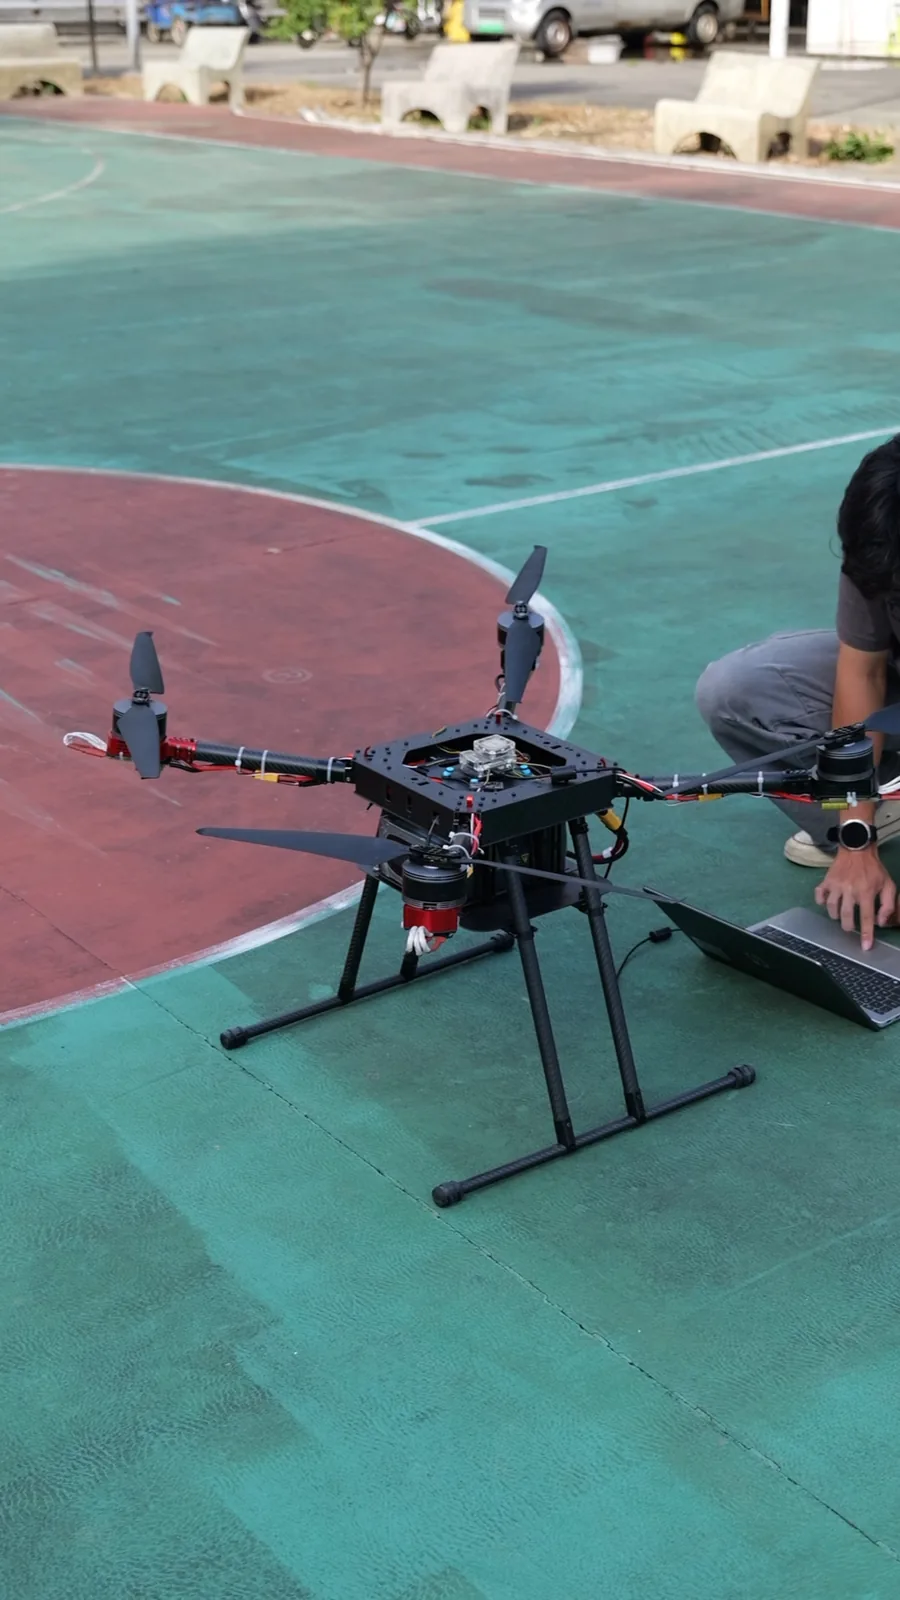
Traditional PWM and DShot ESCs work well on small and medium FPV platforms. But once you step up to a 22-inch heavy-lift UAV — more axes, longer arm wiring, higher per-motor current, and a noisy electromagnetic environment — the weaknesses of a one-way PWM signal bus start to dominate. A CAN (DroneCAN) ESC is the more suitable choice for industrial heavy-lift airframes. This article uses our fully assembled and test-flown 22-inch heavy-lift platform as a case study.
Why Traditional PWM ESCs Struggle on Heavy-Lift Airframes
Messy, Heavy Point-to-Point Wiring
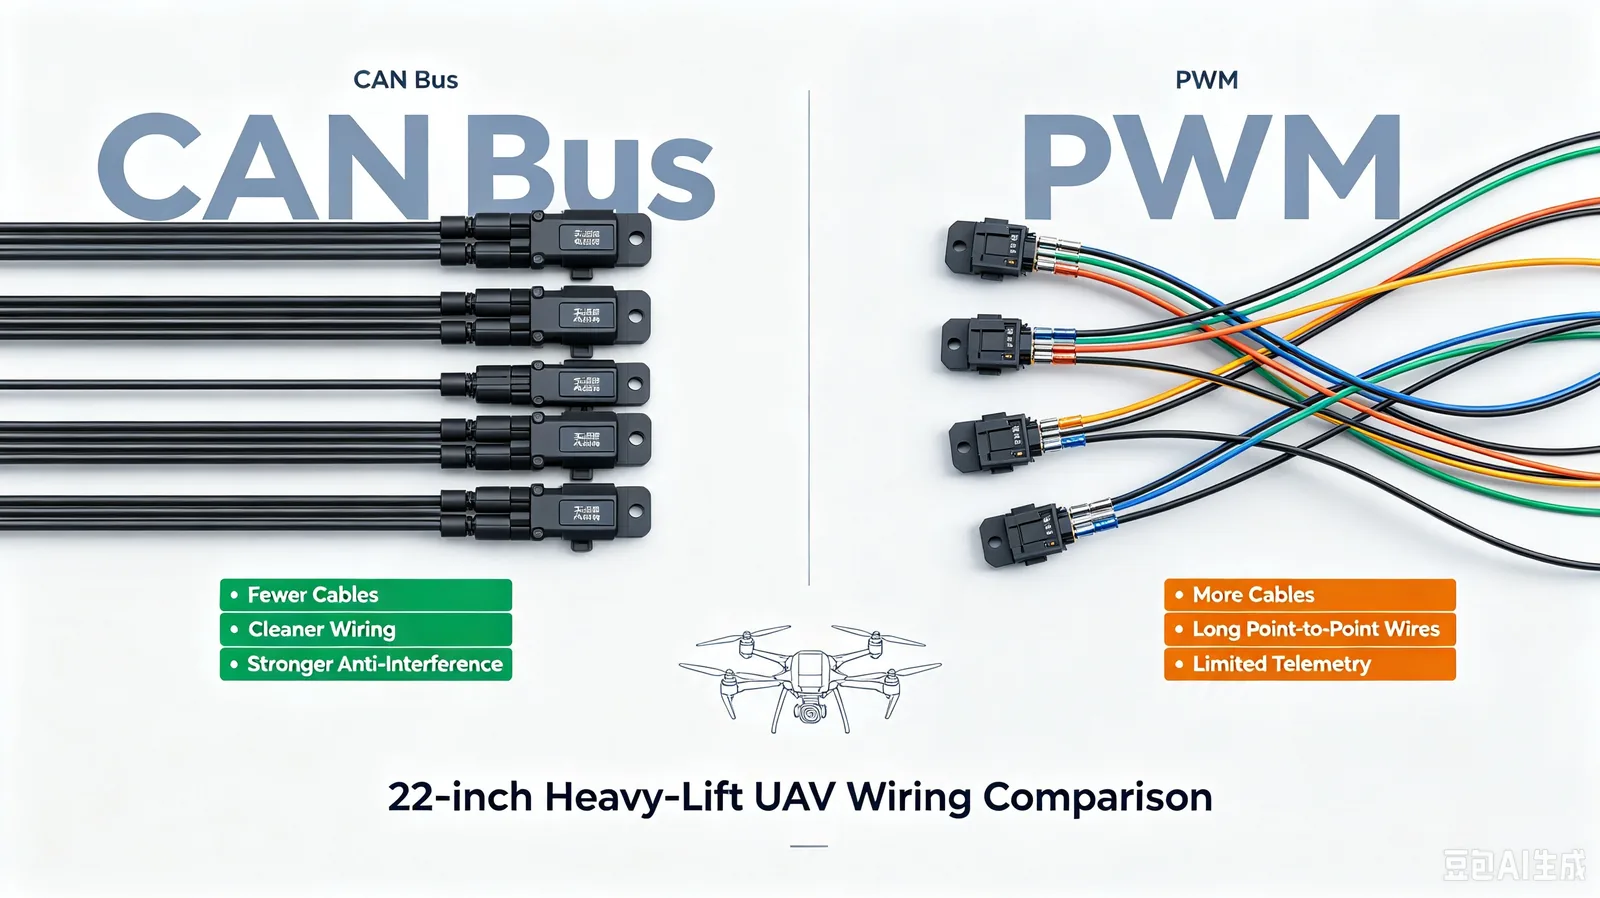
PWM uses one-way, point-to-point signal transmission. Every motor needs its own signal wire running back to the flight controller. On a hexacopter or octocopter that means a dense bundle of cables through every arm — messy, laborious, and dead weight.
EMI, Signal Loss and Speed Fluctuation
PWM is a single-ended signal. Over long arm wiring it is easily disturbed by electromagnetic noise from high-current power wires, causing packet loss and motor speed fluctuation.
No Telemetry, No Fault Trace
A PWM ESC only receives throttle commands. It cannot report temperature, phase current, RPM, or fault codes. In flight you are blind to each power unit’s health.
How CAN (DroneCAN) ESCs Solve These Problems
Far Fewer Wires, Lower Weight
Multiple ESCs share the same two-wire bus, so signal cables drop from one per motor to one shared pair. Wiring is simpler, and saved cable weight is payload you can use.
Strong Noise Immunity on Long Arm Runs
Differential signalling rejects common-mode noise. On heavy-lift arms with long runs and high adjacent current, CAN is far less prone to EMI-induced packet loss.
Bidirectional Full Telemetry
CAN ESCs report back ESC temperature, bus current, motor RPM, and fault alerts. The ground station continuously monitors every power unit and raises early warnings.
No Throttle Calibration
CAN removes the throttle-range calibration that every PWM ESC requires, shortening assembly and testing time.
When PWM ESCs Still Make Sense
PWM ESCs are simple and low-cost, and remain the right choice for small, low-axis platforms that do not need telemetry. For 22-inch-class, multi-axis, high-reliability industrial heavy-lift aircraft, the CAN bus solution delivers a clear overall advantage.
The WBP CAN ESC Product Lineup
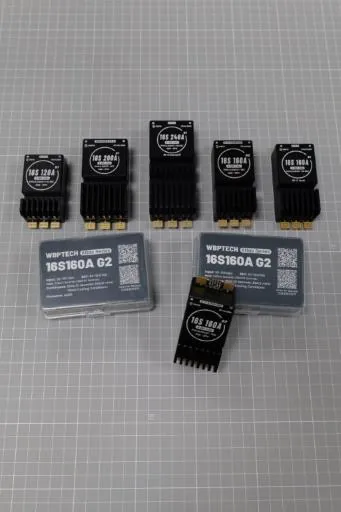
For the heavy-lift market, WBP has built a complete DroneCAN ESC portfolio covering multiple voltage and current ratings, compatible with multirotor and VTOL platforms using 22-inch or larger propellers:
- Optimized heat-dissipation structure for continuous industrial heavy-load duty.
- Full DroneCAN telemetry (temperature, current, RPM, fault codes).
- Native compatibility with PX4 and ArduPilot.
- Ready for airframe integration and OEM development.
Frequently Asked Questions
What is the difference between CAN (DroneCAN) and PWM ESCs?
PWM uses one wire per motor and only sends throttle one way. CAN uses a shared two-wire differential bus, supports bidirectional telemetry, needs no throttle calibration, and rejects EMI.
When should I choose a CAN ESC over PWM?
Choose CAN for 22-inch-class or larger multi-rotor/VTOL platforms carrying heavy payloads on long missions. Choose PWM for small, low-axis builds without telemetry needs.
Do CAN ESCs work with PX4 and ArduPilot?
Yes. DroneCAN ESCs are natively supported by both, with telemetry displayed in the ground station.
Does a CAN ESC need throttle calibration?
No. The DroneCAN bus handles command delivery digitally, so the traditional PWM throttle-range calibration step is not required.
Technical References
- DroneCAN Protocol Documentation
- PX4 Documentation: docs.px4.io
- ArduPilot Documentation: ardupilot.org